

DEEP Robotics LYNX M20S
- Back payload
- 35 kg
- Unloaded runtime
- 3.5–5 h
- Operating speed
- 2 m/s



Price on request · Available to order
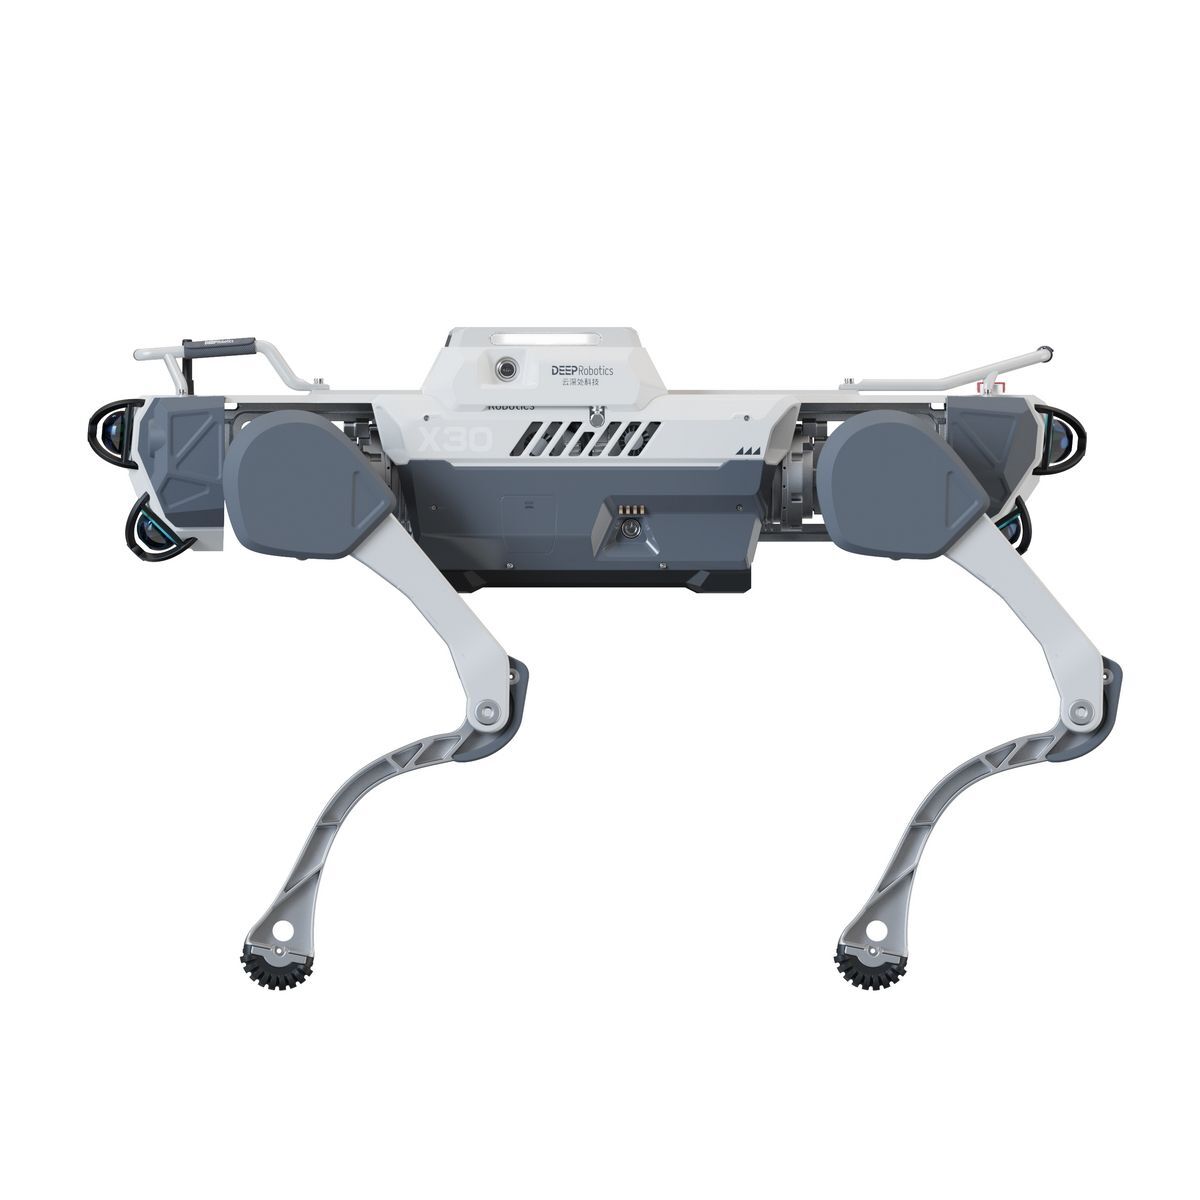
DEEP Robotics X30 Pro is an industrial quadruped platform for inspection rounds and transport of measurement equipment. The Pro version combines legged movement with multi-sensor perception, mapping, localisation and path planning. It is relevant to projects that need an instrument to reach observation points through stairs and uneven areas, then collect information about the condition of equipment.
An inspection round consists of transfers and stops at selected assets. A developer can build a sequence in which X30 Pro reaches a location, takes a useful position and lets the installed module acquire its reading. Mobility and data collection then become parts of one process. The instrument, viewing direction and acceptance criteria are selected for the particular equipment being inspected.
The legged structure supports routes containing stairs and changes in level. Stair geometry and the contact surface matter during travel, while instrument stability matters at the observation point. An upper assembly includes the weight of its brackets and equipment, together with their effect on body balance. The working configuration needs to support both movement and data collection without changing the equipment between those stages.
Pro includes sensor fusion and calibration, multi-sensor mapping, localisation and path-planning algorithms. These provide a foundation for movement relative to the surroundings. The integrator connects that foundation to an application sequence: selecting checkpoints, defining when recording starts and processing the result after arrival. Assessing the condition of the inspected asset belongs to the measurement application's logic.
A controllable lighting system helps organise observation where illumination is limited. Its use should follow the installed instrument: an overview image and another measurement method may need different conditions. Platform perception supports movement through the environment, while the added instrument still needs an appropriate viewing direction and a clear field around its target.
USB, Ethernet and Wi-Fi support connections between project components, and power interfaces serve the payload. The manufacturer specifically lists industrial 12/24 V power support for Pro. The application computer and instrument should work together: accept a command, relate a reading to the right stop and pass the result onward. Mechanically attaching a sensor is one stage within that wider integration.
Secondary development allows X30 Pro to become the basis of a custom inspection solution. Application design defines what counts as arrival, when an observation has finished and how its output is used. This connects the platform's navigation functions to a useful operating procedure, instead of treating travel and measurement as unrelated tasks.
A quick-removal battery and support for autonomous charging help organise repeated outings. Round duration depends on the actual payload and terrain, with service time included between jobs. The IP67 rating applies within the manufacturer's conditions rather than describing every possible operating situation. For a UAE industrial robotics project, X30 Pro supplies a mobile and navigation foundation; the measurement payload and inspection logic are defined by the chosen application.


Tell us about your task, site and robot. Leave your contact details so we can discuss the scope and next steps.